Applications of Cartesian robots
Injection molding machine unloading
Remove the part within the machine's available time window.
The process
From opening the mold to delivering the part.
Removal must respect the mold opening, the extraction position and the injection molding machine's permission signals. In addition to reaching the part, the robot must leave the area within the available time and deliver the product without compromising the cycle.
Architecture to evaluate
CR-NX-1C
The single-column structure is the initial reference for injection molding outlets. Selection depends on machine access, product and trajectory.
Compare CR-NX models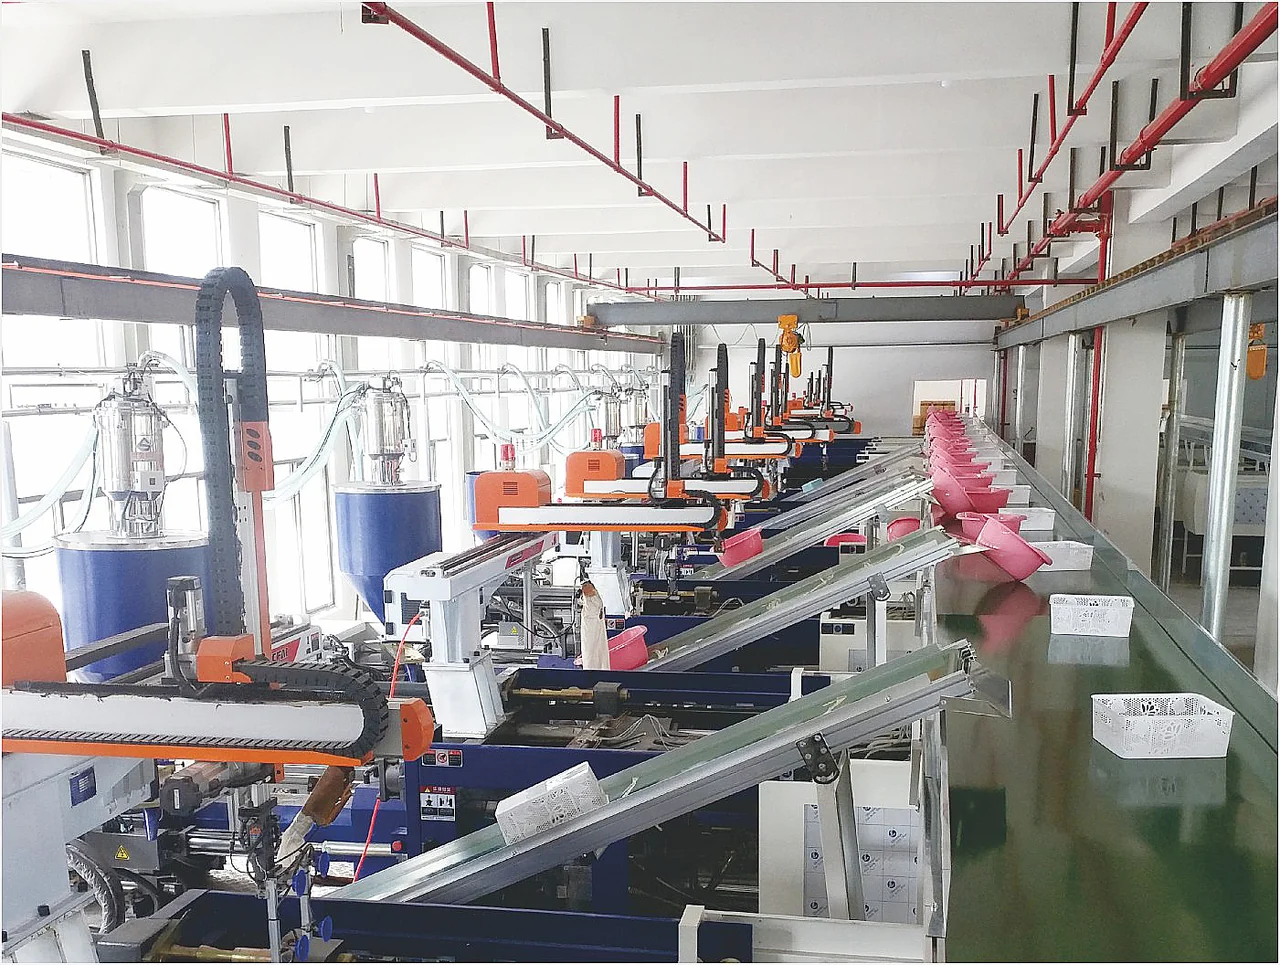
How it works
The operation in 3 steps.
- Clear the infeed
With the mold open and extraction in the expected position, the injection molding machine allows the robot to enter. This exchange of signals coordinates the withdrawal and prevents the sequence from progressing before the machine is released.
- Grip and remove
The gripper collects the part at points defined for its geometry and temperature. The robot travels along the exit path, respecting mold interference and the time available to release the closing area.
- Deliver the product
Outside the mold area, the robot places the part on the support or conveyor, in the orientation necessary for the next operation. Releasing the gripper and returning to the standby position completes the sequence.
Before sizing
The data that makes a difference.
- Part, injection channels, temperature and possible grip points.
- Mold opening, extraction position and interferences.
- Time allowed for entry, pick up and exit of the robot.
- Permission signals, interlocks and safeguards for the system.
Conditions to evaluate
- The gripper must suit the part geometry and temperature.
- The trajectory must respect the mold, columns and machine components.
- Timing and protections are evaluated in the robot–injector assembly.
What to validate upon delivery
Collection and delivery sequence validated with representative parts and synchronization with the machine.
Discover our approachConnect the steps
Explore related processes.
Shall we evaluate injection removal in your operation?
Discuss this application with our engineering team. You can provide product, cycle time and layout details when you contact us.