Injection molding machine unloading
Remove the part within the machine's available time window.
- Clear the infeed
- Grip and remove
- Deliver the product
Applications
From part removal to pallet formation: discover the Cartesian robot's role in each operation and the data that guides its configuration.
Explore the applicationsFrom infeed to outfeed
Choose a process to see its sequence, key considerations and the CR-NX architecture to assess.
Remove the part within the machine's available time window.
Repeat transfers with defined position and orientation.
Connect stages without making transfers a bottleneck.
Organize product infeed and case packing.
Build layers and prepare production output.
Remove products from the pallet and feed the next stage.
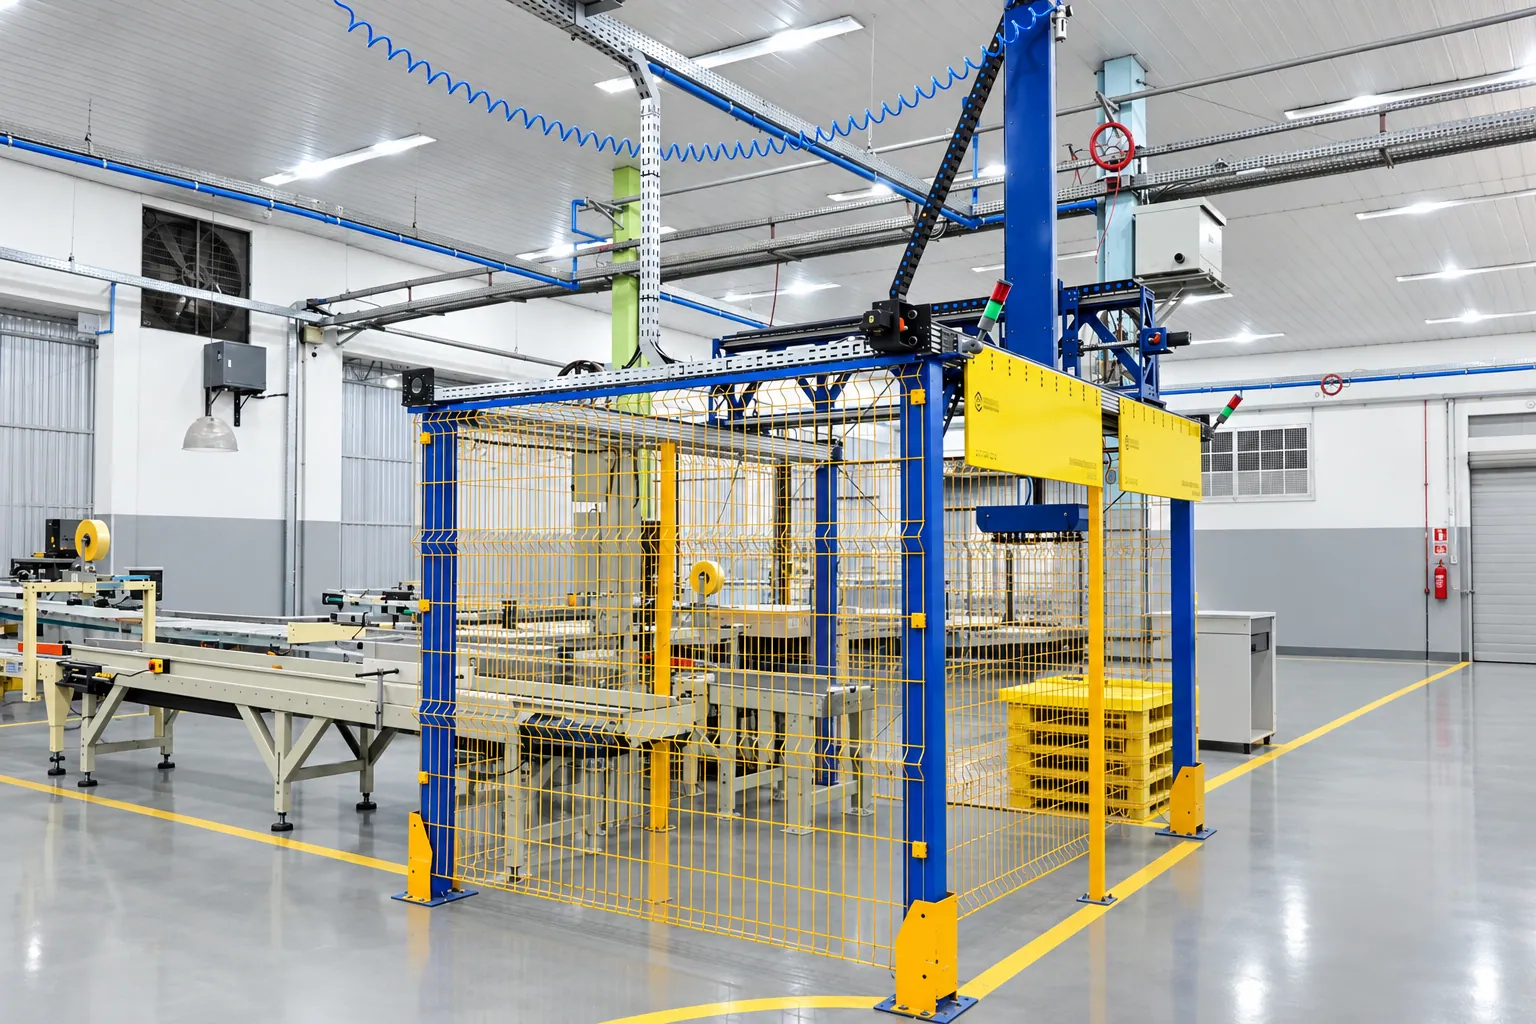
An application in operation
At Midiograf, Cartesian robots connect the output of folder-gluers to the arrangement of boxes on pallets.
Learn the context of the integration, see the installation and follow the team's report on the operation.
See photos, video and Midiograf's reportExplore the flow
Open a step to learn about the problem and application criteria. The scheme represents integration possibilities; it is not a project layout.
Remove the part within the machine's available time window.
See the criteria for this application ↗Repeat transfers with defined position and orientation.
See the criteria for this application ↗Connect stages without making transfers a bottleneck.
See the criteria for this application ↗Organize product infeed and case packing.
See the criteria for this application ↗Build layers and prepare production output.
See the criteria for this application ↗Remove products from the pallet and feed the next stage.
See the criteria for this application ↗Share the complete sequence, from product input to output. Let's evaluate the required interfaces and configuration.